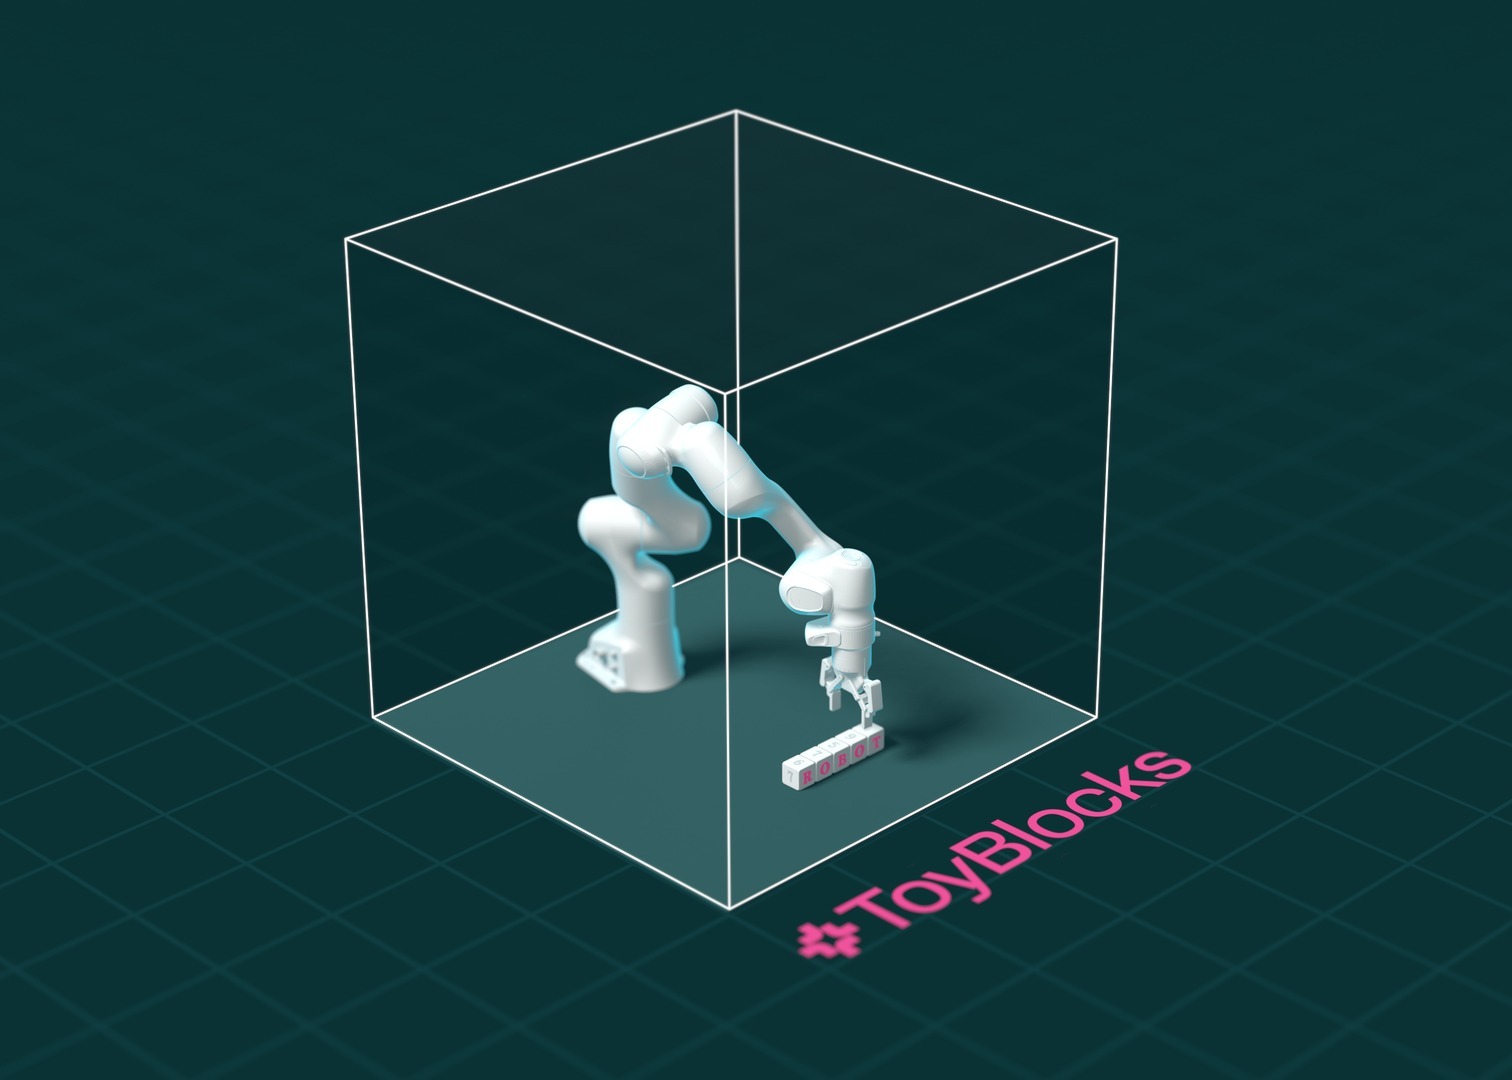
A simulated robot arm environment that generates training data and tasks automatically without teleoperation. It uses reinforcement learning in Isaac Lab to create skills for pushing and flipping blocks, paired with a task-and-motion planner to sequence those actions. This replaces the manual process of recording human demonstrations for manipulation tasks.
It is useful for isolating how models handle reasoning versus dexterity in a closed loop. The trade-off is the narrow scope, as the physics and objects are simple enough to be fully controlled but too limited to predict performance on unstructured real-world clutter. Skip it if you are testing end-to-end policies on complex, open-ended scenes.


Leave a Reply